
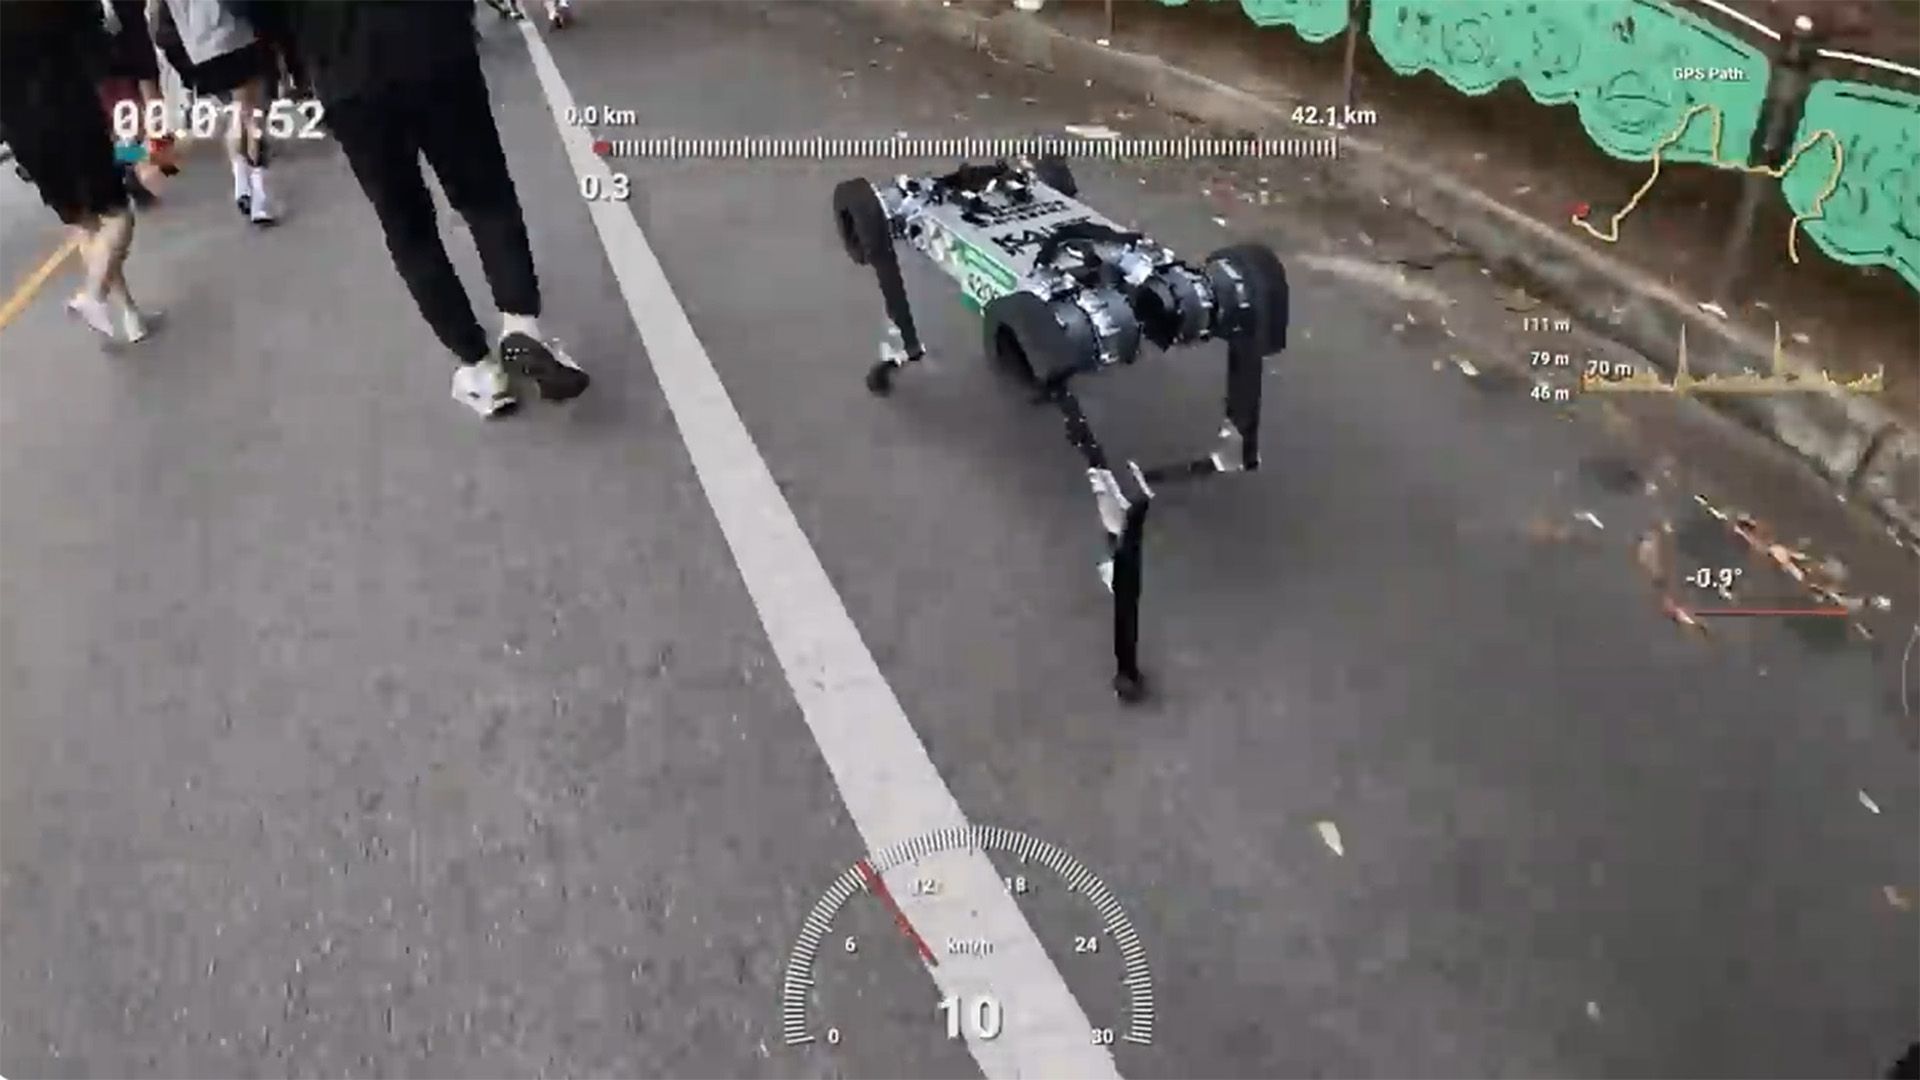



A four-legged robot completed a full marathon on a single battery charge, covering 26.2 miles (42.2 kilometers) on a hilly public-road course in South Korea two years ago. Now we know a lot more about how it achieved this record-breaking feat.
The dog-like robot, called RAIBO2, finished the 22nd annual Sangju Dried-Persimmon Marathon in just over 4 hours, 19 minutes. The bot’s developers say it’s the first quadruped robot to have completed an official marathon-distance event without stopping to recharge. They’re commonly referred to as “robot dogs” because the movement of their joints in both front and hind legs resembles that of canines.
The scientists outlined their findings about the robot’s feat, which it achieved Nov. 17, 2024, in a study published Sept. 23 in the journal Nature.
Latest Videos FromLive Science
This achievement represented a new milestone in overcoming a critical limitation for quadruped robots: endurance. Although four-legged robots can cross difficult terrain that wheeled machines struggle to traverse (like stairs and rugged trails), their endurance has been limited because powering multiple joints while repeatedly lifting and stabilizing the machine’s body consumes huge amounts of energy.
“Unlike wheeled robots, quadrupeds continuously expend energy at their joints to support body weight and incur kinetic energy losses during intermittent foot-ground contact,” the researchers wrote in the study.
Watch On
RAIBO2’s race was a demanding real-world trial. It took place during the Sangju Dried-Persimmon Marathon, with the bot racing alongside human participants. The route covered two 50-meter [164 feet] elevation climbs, with slopes of up to 10 degrees. Those kinds of gradients put increased strain on the robot’s energy resources, stress-testing the bot’s battery management capabilities, the scientists said.
RAIBO2 had previously run a 26.7-mile (43 km), GPS-guided route across a flat athletic field, which it knocked out in 4 hours, 40 minutes on one charge. However, an earlier marathon attempt across uneven terrain against other competitors had to be aborted around the 23-mile (37 km) mark after the robot’s battery ran out. The robot’s developers attributed that shortfall in part to frequent pace changes as the machine attempted to adjust to the pace of nearby runners.
Get the world’s most fascinating discoveries delivered straight to your inbox.
To compensate, the team boosted the robot’s battery capacity by 33% and tinkered with the control system, including implementing joint-stiffness control at the actuator. This allowed the bot to soften its leg when it had to absorb an impact or it needed a stable, forceful push-off. After the adjustments, RAIBO2 expanded to a maximum range of 41.6 miles (67 km) on a single charge, albeit on straight paths, according to the researchers.
Another key metric was RAIBO2’s total cost of transport — a measure of the energy required to move a body over a given distance, with lower values indicating less energy expended. Researchers reported that RAIBO2 achieved a total cost of transport of 0.25, compared with a human benchmark of 0.37. The researchers said their machine was the first quadruped robot to surpass that figure.
The team attributed that efficiency to several optimizations across RAIBO2’s software and hardware. Especially vital were its lightweight mechanical components, which were capable of transmitting kinetic energy from its joints with very little interference. They also credited a low-loss motor-driving circuit and, on the software side, a locomotion policy specifically streamlined to limit energy use. The system was also trained using the team’s simulation environment, called RaiSim, which includes models of slopes, stairs and icy roads.
Like many electric vehicles, RAIBO2 can regenerate some battery by capturing kinetic energy, particularly while traveling downhill. That capability allows it to offset some of the energy it expends while climbing, though it doesn’t eliminate the extra cost of hilly terrain.
The researchers said RAIBO2 has more than three times the travel range per charge of existing quadruped robots, with a total battery capacity of 2,016 watt-hours. It’s in part because of that capacity increase that the team now estimates that the robot could travel up to 15.5 miles (25 km) farther than its marathon stint, up to a total of 41.6 miles (67 km).
That kind of endurance could broaden the roles for quadruped robots in places where wheeled models are impractical, the developers added in the study. For example, they could be useful in disaster zones and mountainous areas, where a sufficiently mobile, high-endurance robot could carry cameras, sensors or communications gear across uneven terrain.
Lee, C., Youm, D., Park, J., Lee, J., Choi, S., Ji, G., Mun, J., Jung, M., Choi, H. C., Kim, H., Oh, H., Nam, K., Lee, M., Hur, J., Choi, D., Kim, D., An, Y., & Hwangbo, J. (2026). A quadruped robot designed to complete a marathon on a single battery charge. Nature. https://doi.org/10.1038/s41586-026-11102-5